Humanoids
Latest Humanoids
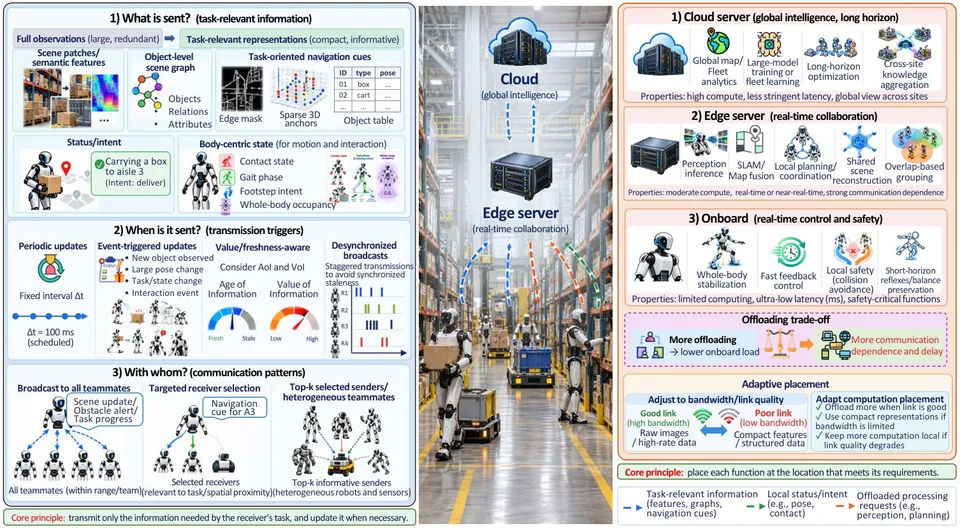
Humanoid Fleets Need More Than Robot-to-Robot Chat
A 2026 arXiv survey proposes networking that treats balance, physical contact, task timing, learning, and human oversight as one engineering problem.
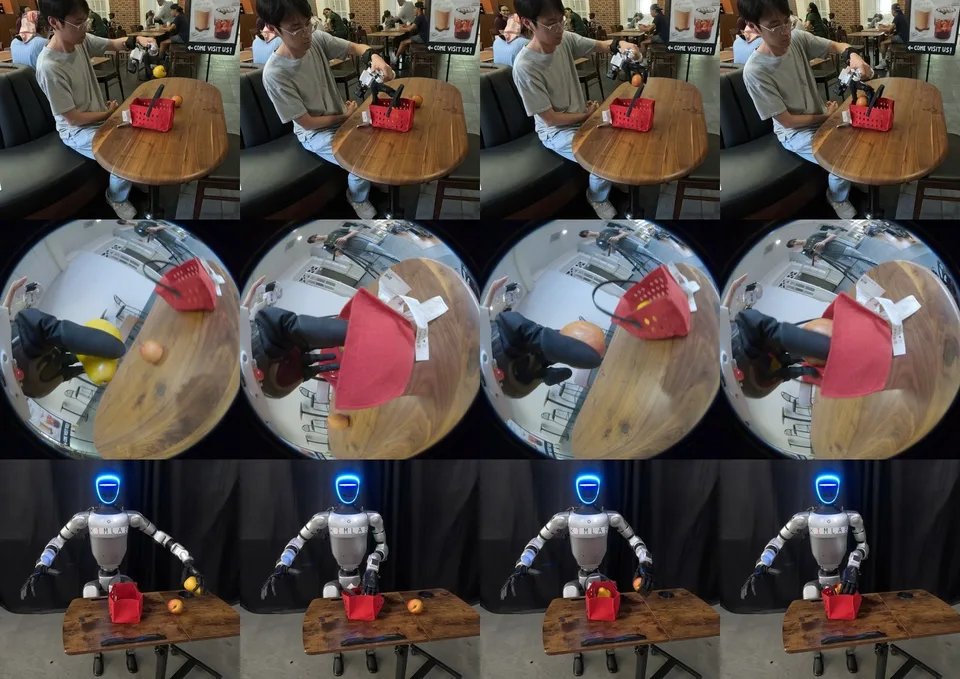
DEX-PHD Turns Handheld Teaching Into Humanoid Replay
The reported research system logs finger motion, contact, and video, then replays selected demonstrations on a physical humanoid robot.
Digit Expansion Targets More Warehouse Sites
Agility Robotics and GXO plan more Digit deployments in early 2027, extending a live warehouse program rather than announcing a finished rollout.
KAIST Humanoid Uses Vision to Move Heavy Objects
A research video shows the robot pushing up to 35 kilograms and lifting up to 20 kilograms while arranging “KAIST.”
Ordinary Robot Requests Can Still Create Collision Risks
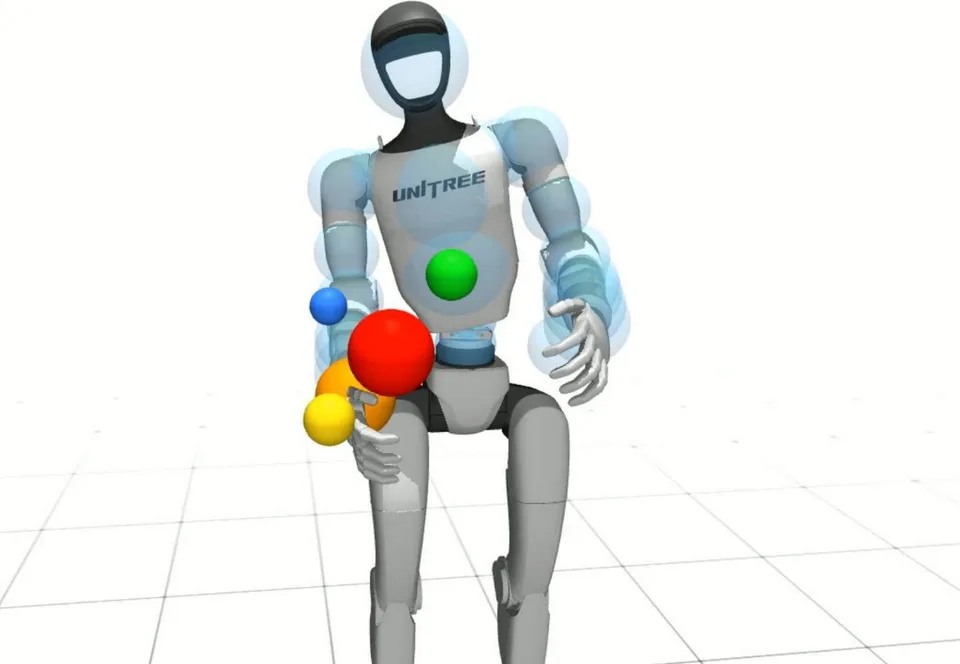
A research paper tested “goal insertion” attacks in simulation and on a Unitree G1, with hardware testing limited to an upper-body task and one static obstacle.
One Reward Setup for Nine Simulated Humanoids
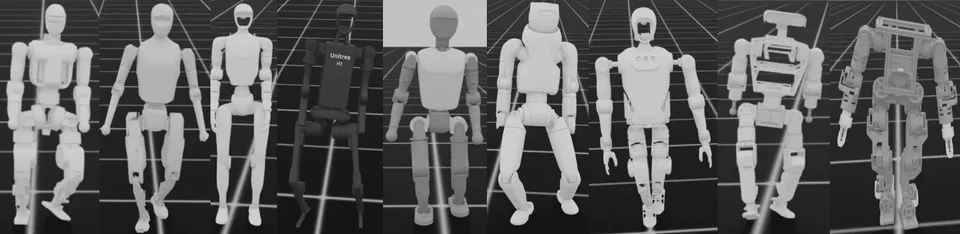
A University of Nevada, Reno paper proposes progress-based rewards to reduce robot-specific tuning in locomotion training.
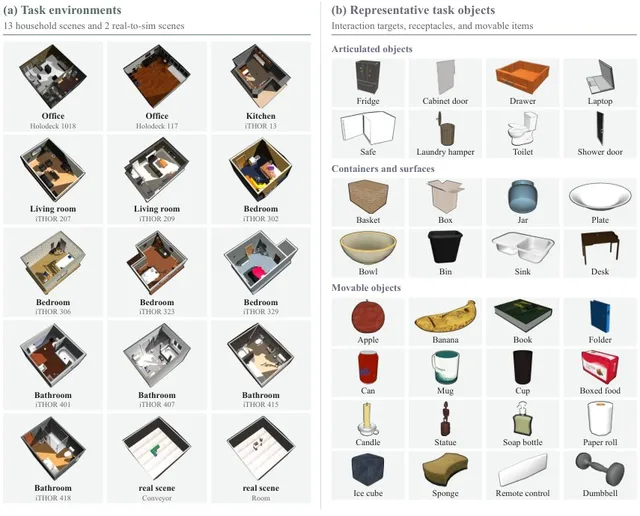
LocoManiLab Tests Humanoids Beyond Familiar Chores
The proposed benchmark combines new tasks, new rooms, controller comparisons, and physical-robot trials.
Humanoid Robots Could Retarget Human Motion More Efficiently
An arXiv paper proposes spending more computation on the moments when a robot touches or moves an object.
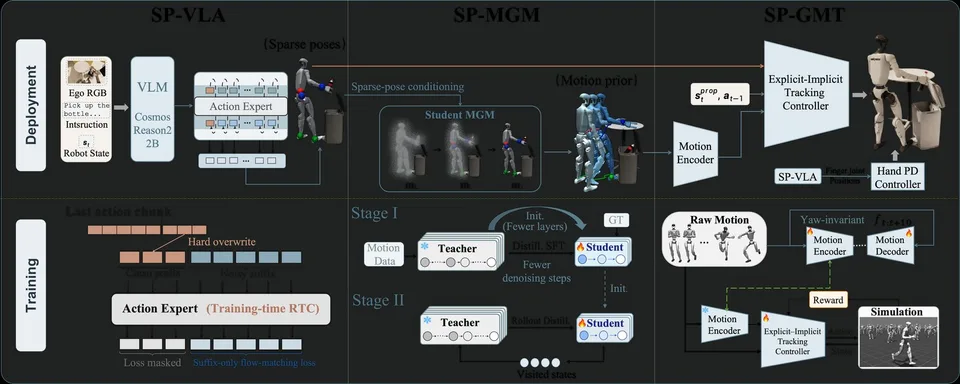
Five Body Targets Guide a Humanoid’s Whole-Body Motion
SP-HLM combines sparse task instructions with a learned motion prior, then tests the approach in simulation and on a Unitree G1.
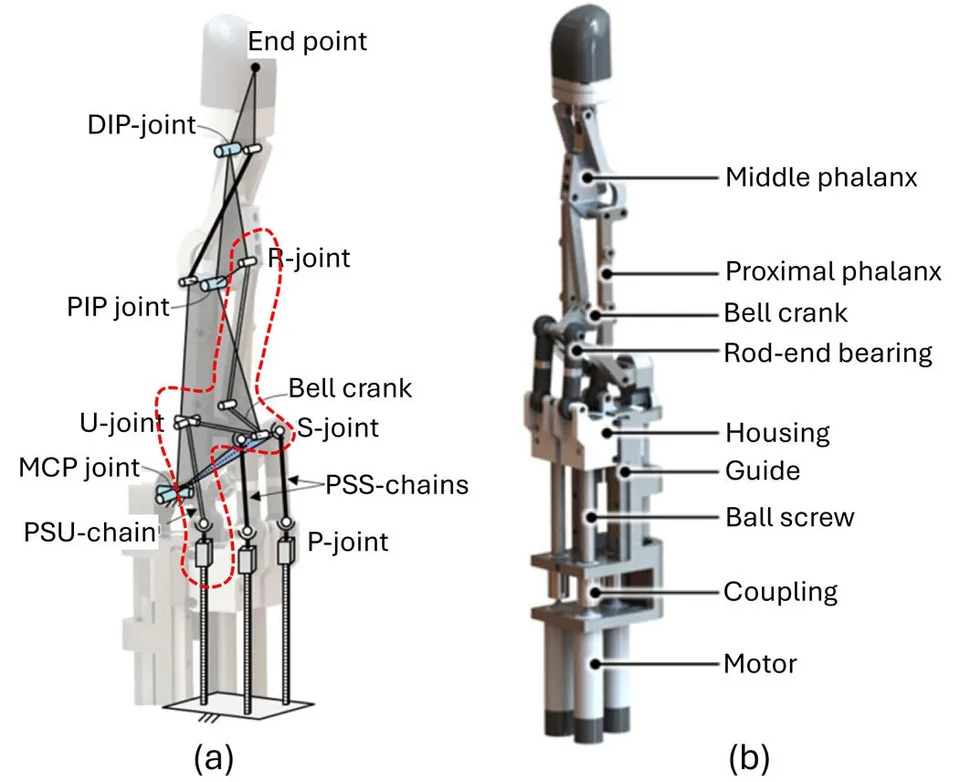
A Simpler Linkage Could Make Humanoid Hands Easier to Build
A New Jersey Institute of Technology paper proposes a printable hand with fewer moving parts, but its durability still needs deeper testing.
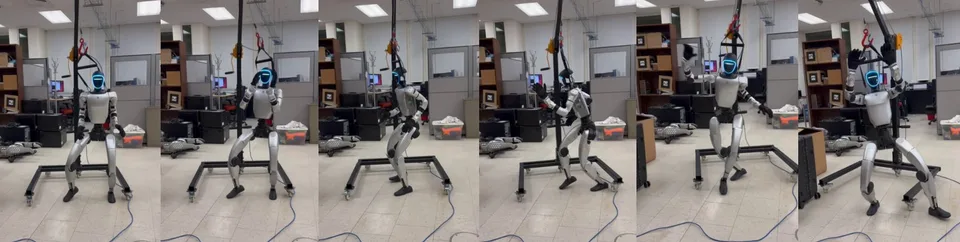
FRDV Converts Human Motion Into Humanoid Robot Moves
A University of Massachusetts Amherst paper reports fast simulation retargeting and a zero-shot Unitree G1 demonstration—not a deployable product.
AGCO Plans Digit Pilot for Parts Handling
Agility says Digit will sort and stack parts and place totes for storage at AGCO’s Kansas factory, with a pilot expected in 2027.
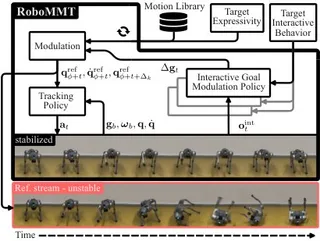
RoboMMT Keeps Expressive Robots Upright
The research demo combines adjustable gestures with balance control and live facing or pointing, but its strongest result excludes spatial-goal changes.
SWAP Lets a Humanoid Choose How to Dodge Obstacles
The research system samples full-body maneuvers at deployment, then favors those matching a chosen goal.
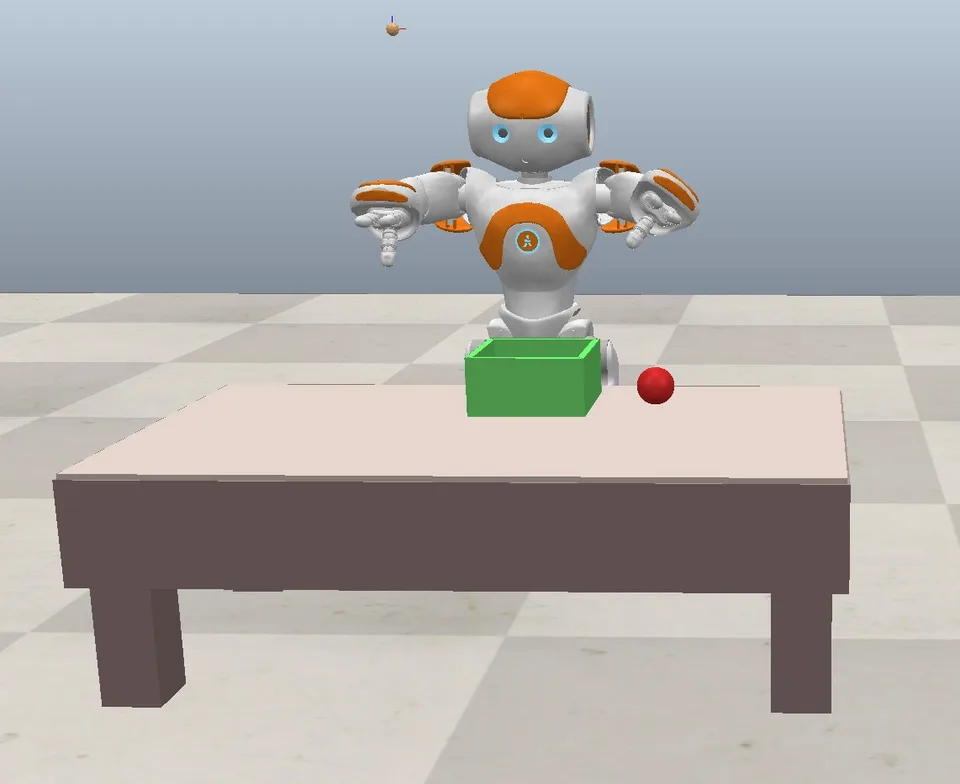
A Smaller Feature Set Helps NAO Learn Robot Tasks
A research paper reports simulation success with 16 demonstrations, while physical tests remain feasibility demonstrations.
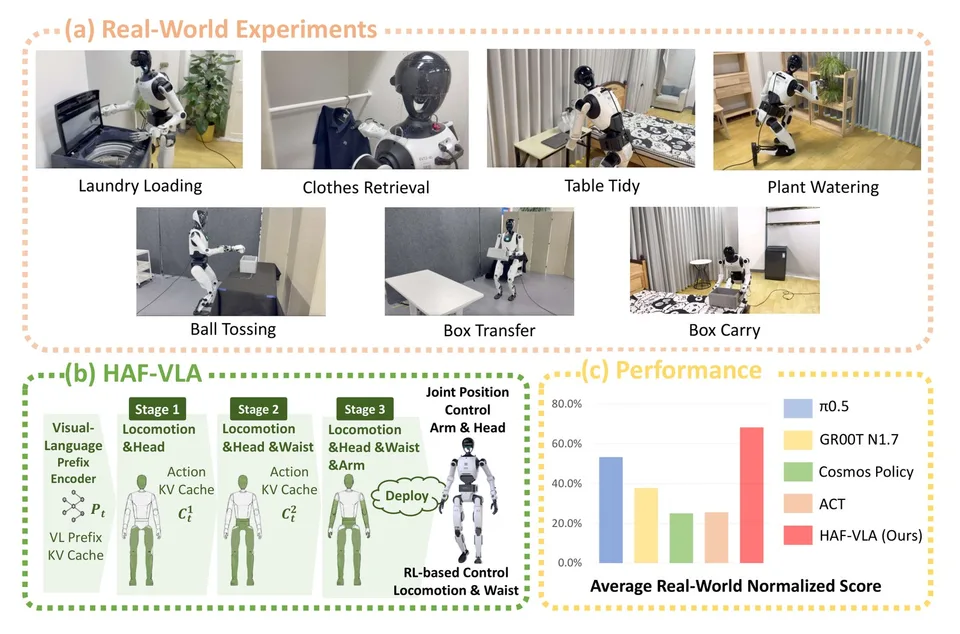
HAF-VLA Plans a Humanoid’s Whole-Body Moves in Stages
A research demo coordinates walking, gaze, posture and hand actions across two humanoid platforms, with reported gains on six real-world tasks.
CoEvolve Revises Robot Teamwork After Failures
The simulation framework changes roles and movement plans while keeping each robot’s motor skills fixed.
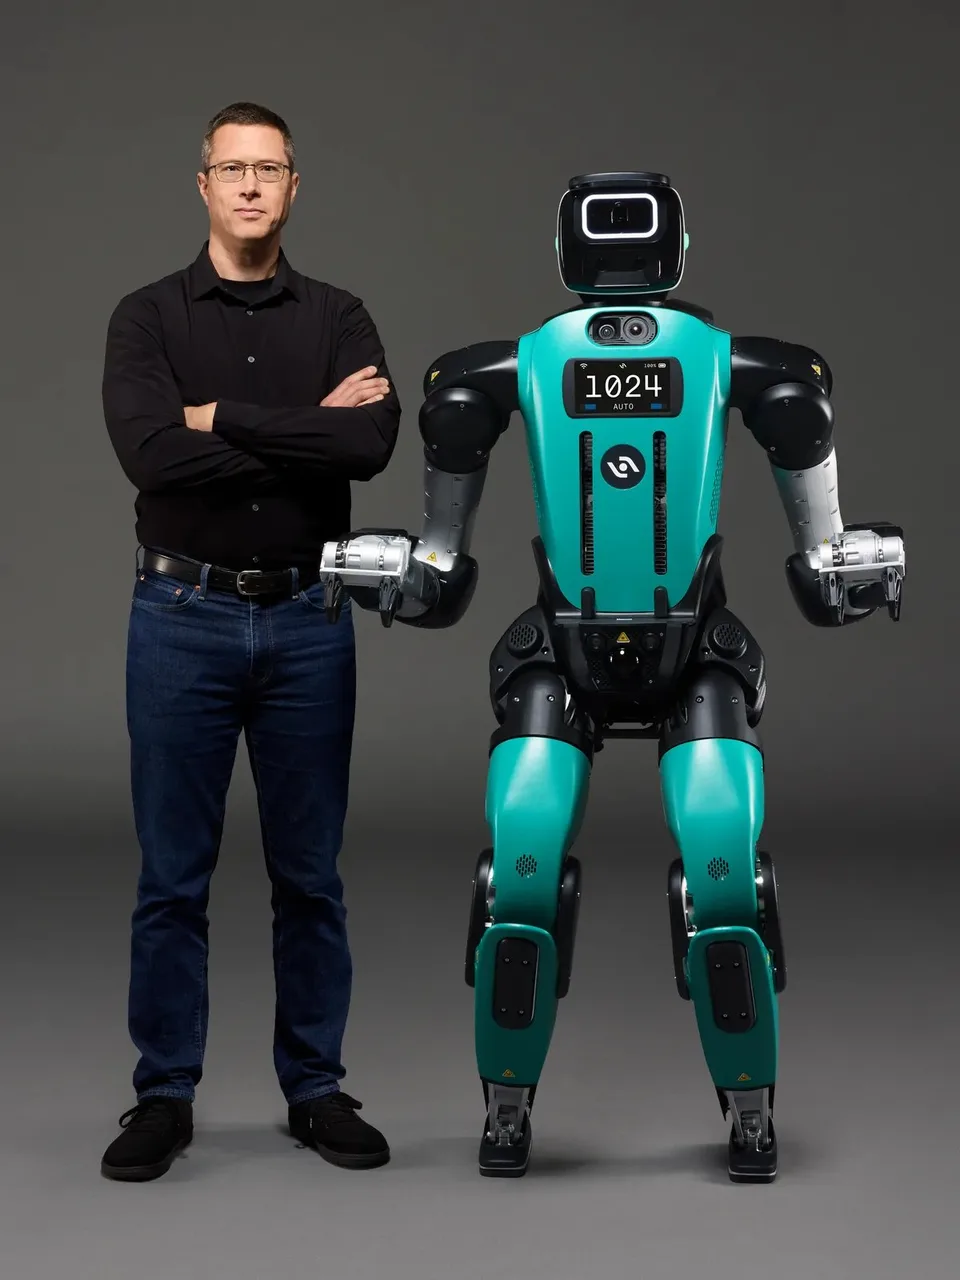
Digit 5 Trades Grace for Safer Warehouse Work
Agility Robotics’ announced humanoid is built for heavy bins, long shifts, and coworkers nearby—not for running or jumping.
Briefing
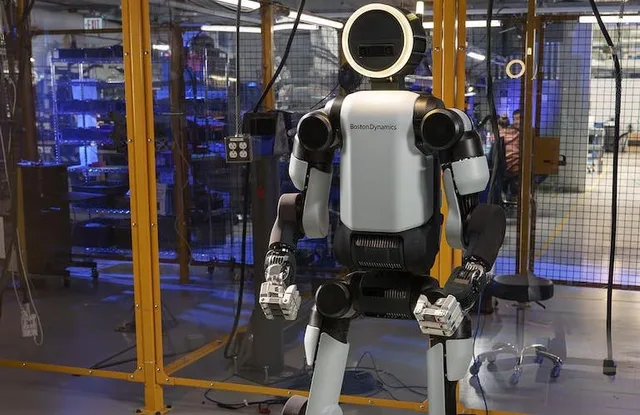
Atlas Learns Factory Work From Human Guidance
Apollo 2 Made Seven Cornhole Shots From Human Video
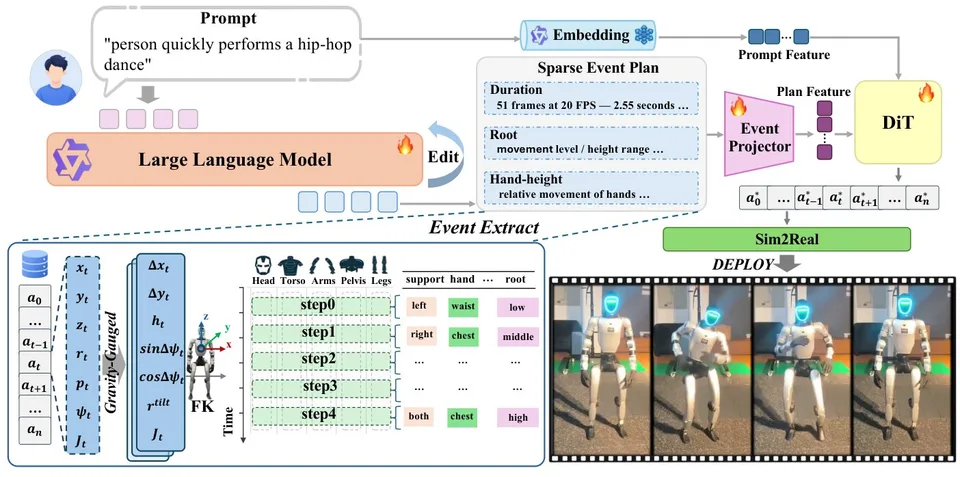
How TRACE Changes One Part of Humanoid Motion
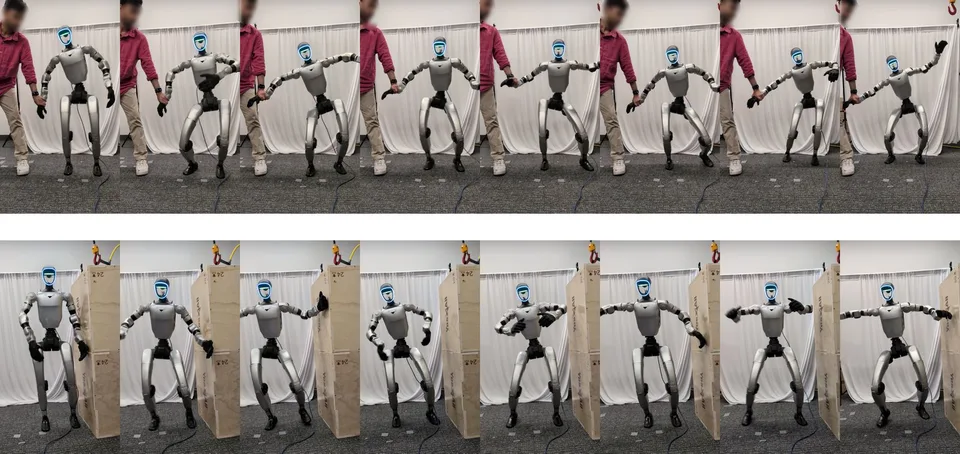
A Unitree G1 Learns to Yield Without Losing Its Motion
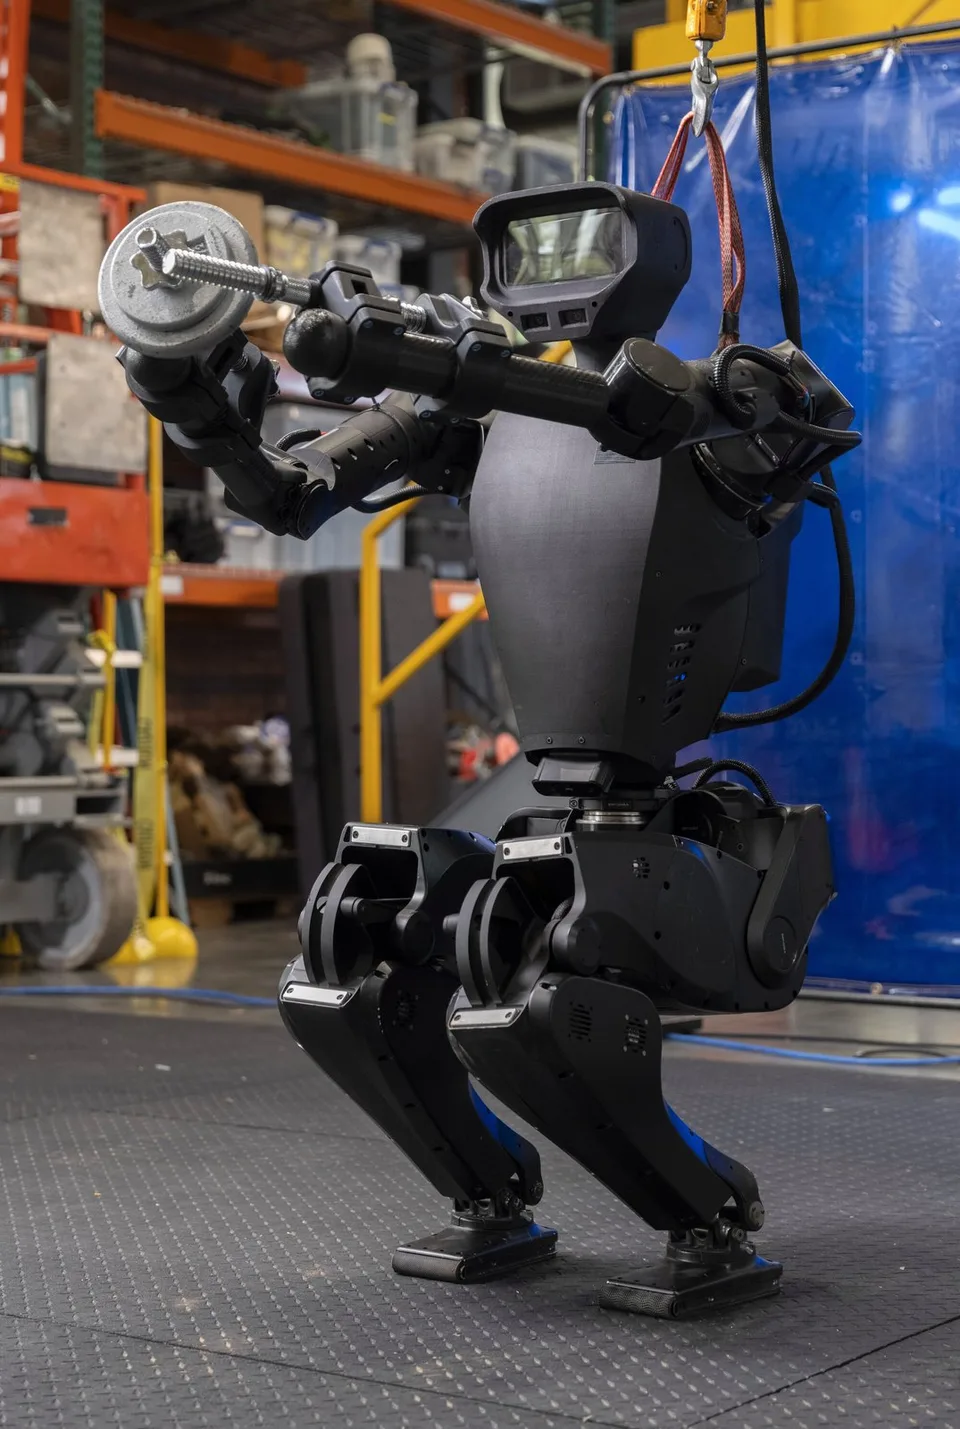
A Humanoid Controller Learns New Loads While It Moves